Elk vs. F-250 → a guard that fights back
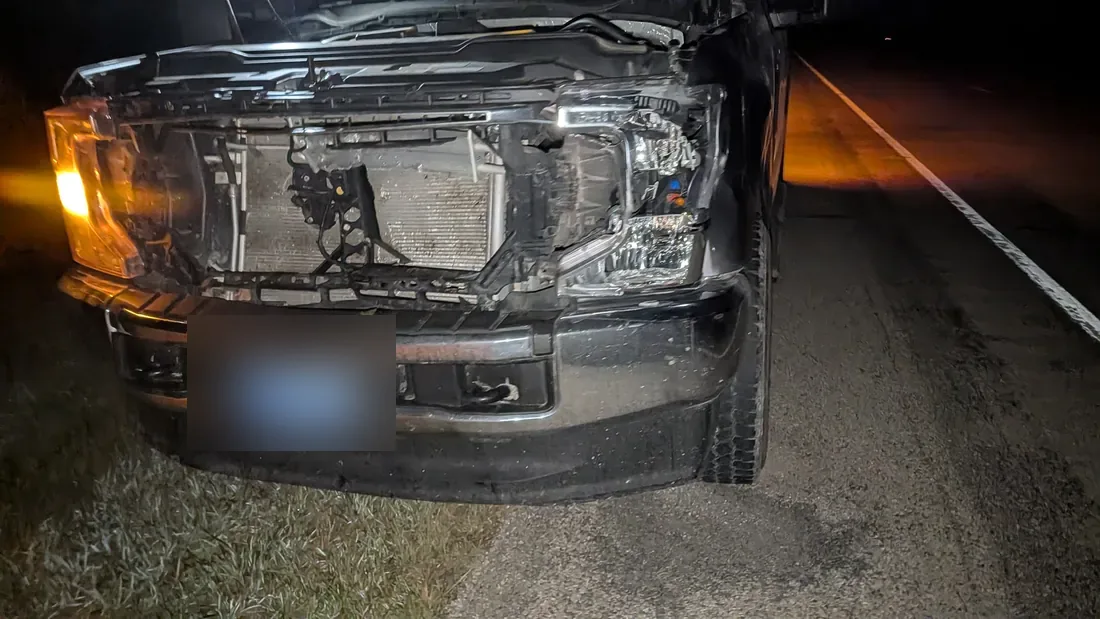
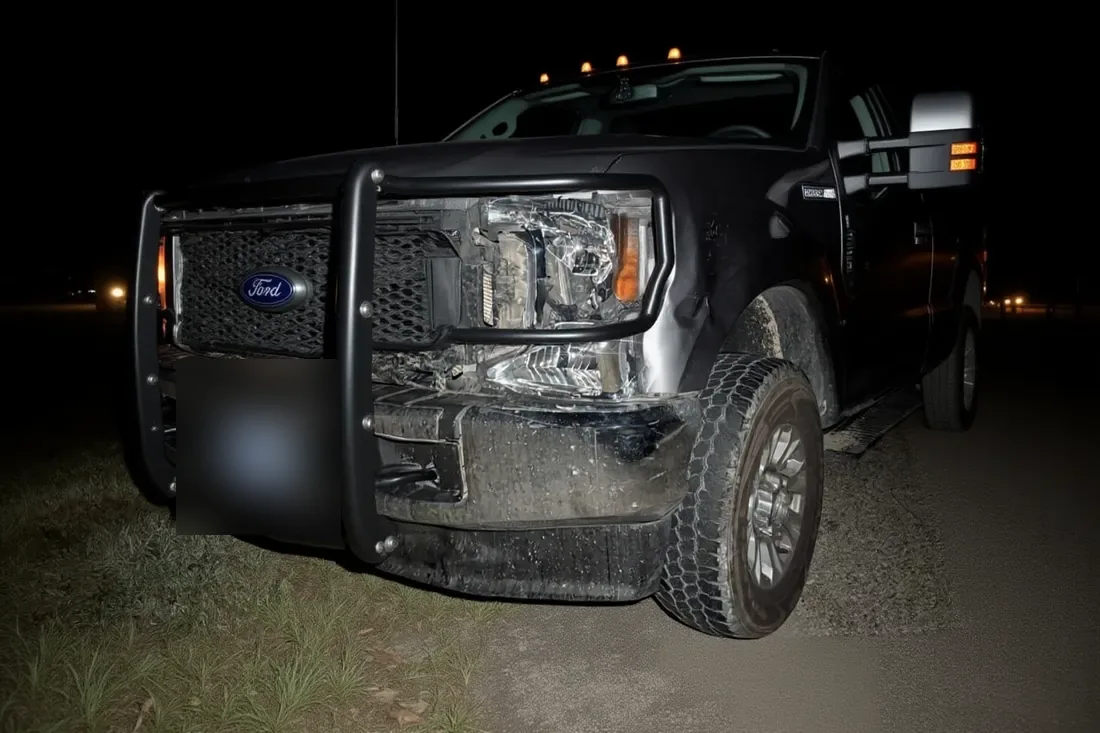
MAd hAT tried 36 guard designs in a computer stress test. The pick held a roughly 43 mph elk hit without folding, in the simulation, using assumed tube sizes. The truck picture is a concept render.
01 · Scan Part
Scan it. Stress it. Build it better.Point your phone at a part or drop in a file. No signup. The MAd hAT optimization engine figures out how to make it stronger, lighter, and cheaper to build.
Computer stress tests on the part you actually have. You tell us the loads; we never make them up.
Your scan becomes an editable 3D copy. Try a few versions, compare strength and weight, keep the winner.
Get a file ready for your 3D printer or CNC. Pick the material and MAd hAT shapes it to suit the machine.
Show us a part (or just describe one). We'll make it better, copy it, or build it new, and hand you files ready to print or machine.
Real jobs
Real parts folks brought us and what came out the other side. Concepts are labeled as concepts, and simulations are estimates, not promises.
MAd hAT tried 36 guard designs in a computer stress test. The pick held a roughly 43 mph elk hit without folding, in the simulation, using assumed tube sizes. The truck picture is a concept render.
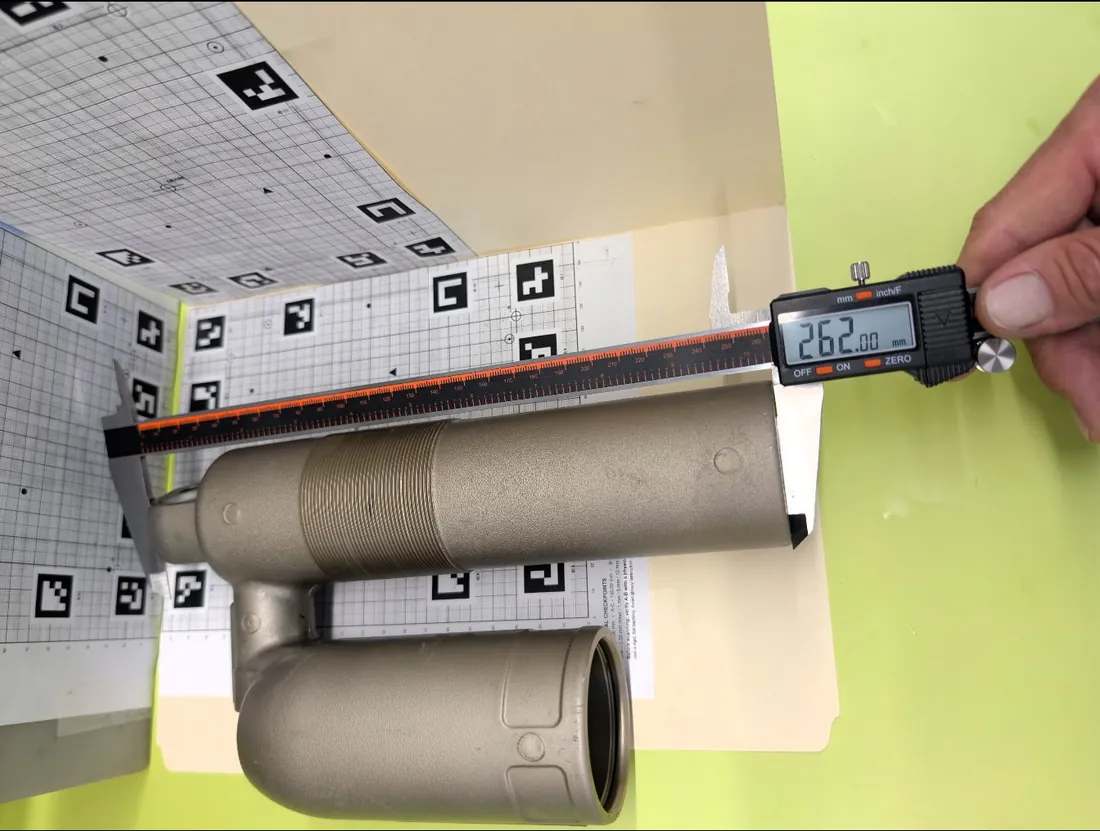
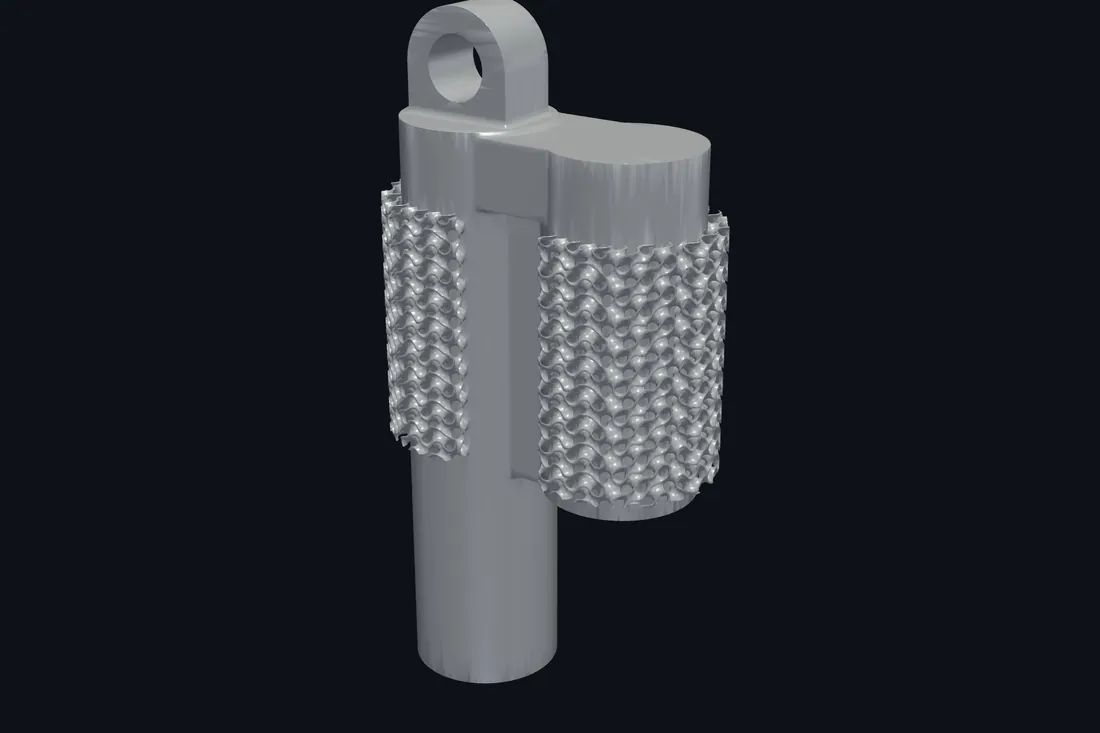
We measured the real shock body, and MAd hAT grew a new one around those numbers. Generated geometry: not yet built or flow-tested.
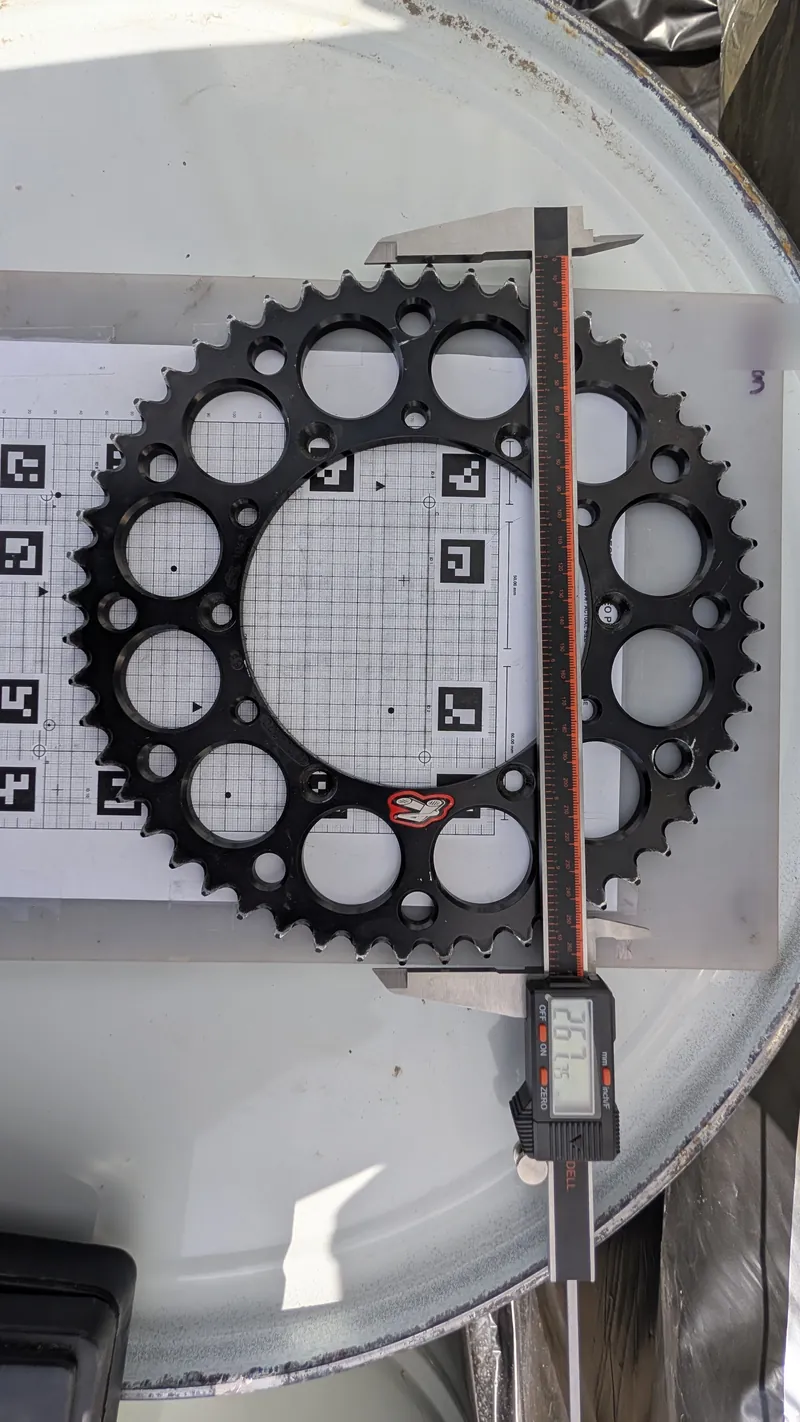
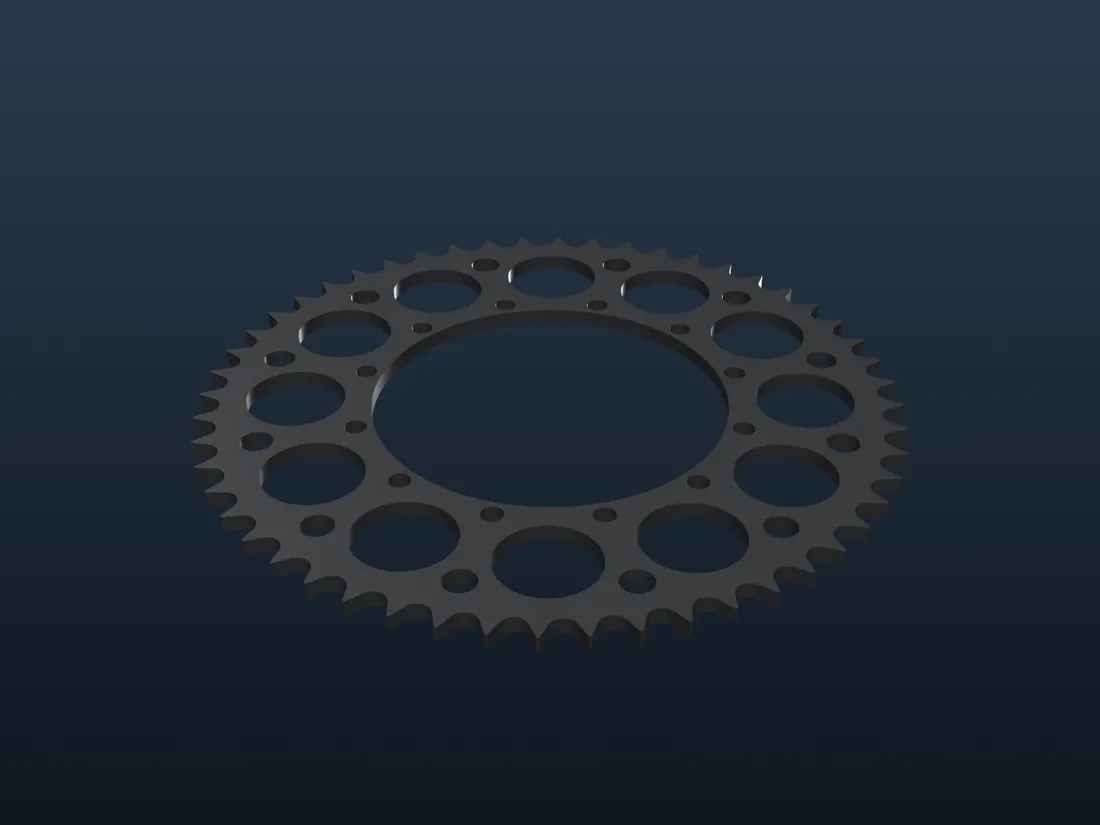
A phone photo on a printed measuring mat became a full 3D model you can print or machine, plus a computer stress test (a simulated estimate).
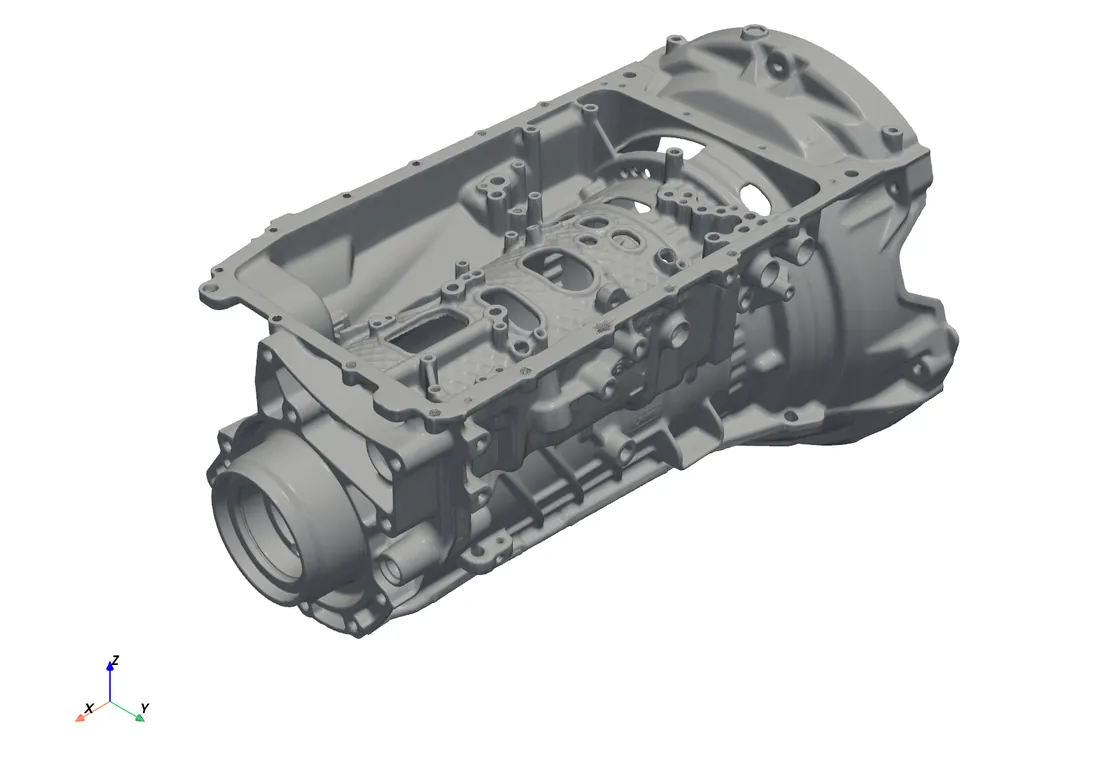
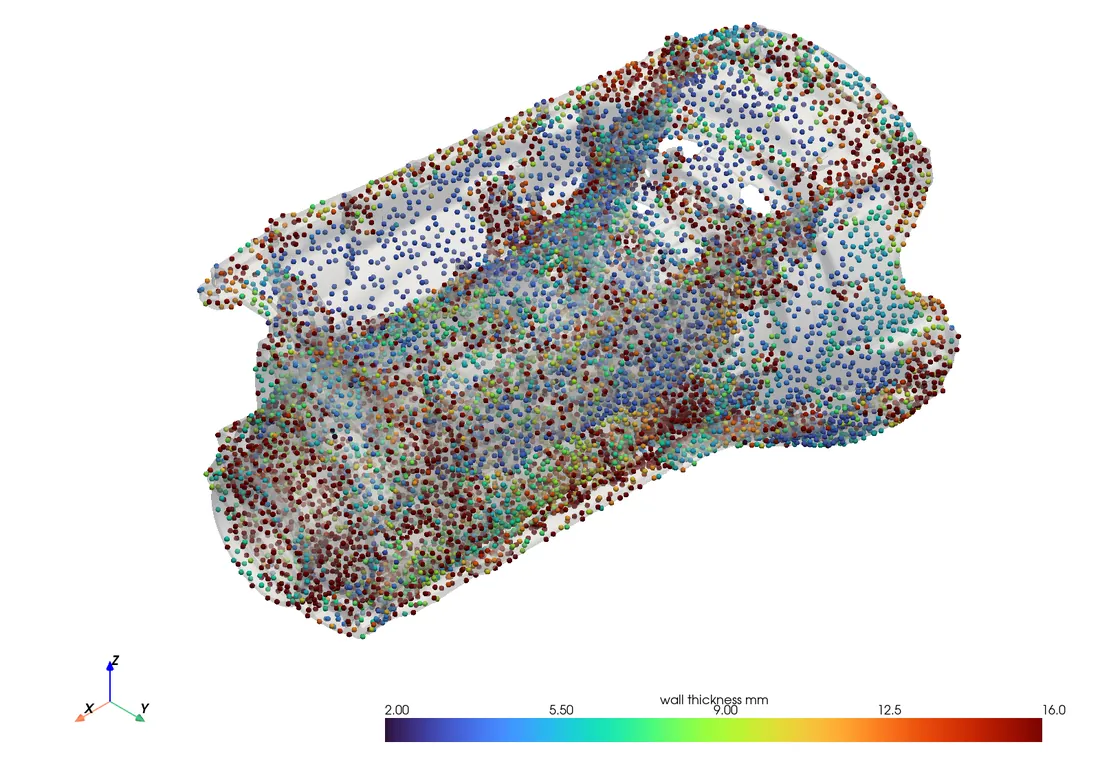
We checked how thick the metal is everywhere on a 6F55 case, about 11,000 spots, so you can see the thin places before you cut, weld or bore.
How it works under the hood
We measure the real part, rebuild it in 3D, stress-test it on the computer, improve it, make it, then measure the result to check our work. Every dimension is tagged as measured, from a photo, or assumed, so a guess can never hide.
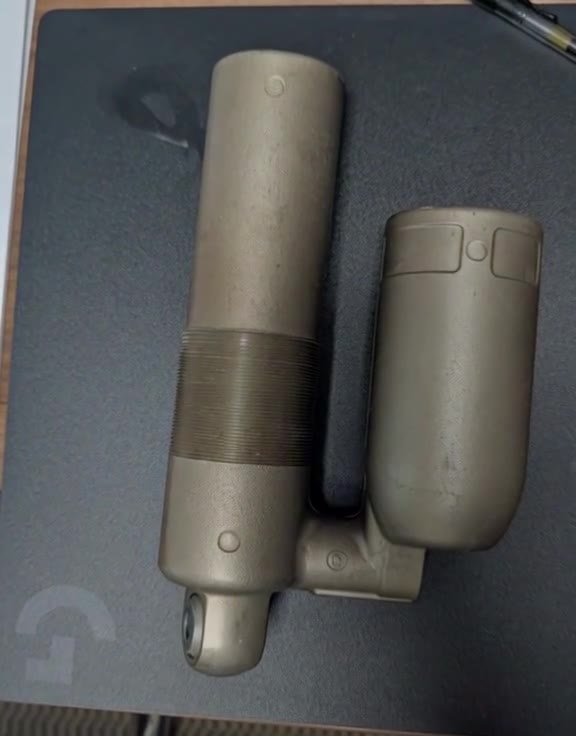
A real motocross shock body, taken from phone photos to a measured digital twin. The same loop runs on every part we take on.
Every ScanIQ job runs the same circuit. The MAd hAT signed-distance geometry engine sits at the center so parametric changes, solver fields and manufacturing output all read from one source. The pulse on the ring is the direction of travel; the loop closes when metrology feeds back into the parameters.
Phone photos, a printed 1 mm ArUco mat and caliper readings become a parametric model in CadQuery, build123d or FreeCAD. Provenance travels with every dimension.
Signed-distance fields make lattices, conformal channels, helicoid blades and fluid negative space ordinary operations instead of mesh surgery.
Static FEA, mode shapes, Goodman/Basquin fatigue, OpenFOAM k-ω SST, 1-D exhaust acoustics and EM field maps. AXIOM, the AI engineer, states the question and the pass rule before a solver runs.
Multi-agent proposals ranked against the stated objective and constraints. Agreement raises confidence; disagreement goes to a human, never averaged away.
STEP, STL, drawings and G-code out. Calipers and photos on the finished part close the loop and correct the parameters.
The KYB PSF2 fork cap v2 is rebuilt as a parametric revolve. Caliper-locked dimensions cannot drift during optimization. Dimensions nobody has measured yet remain [ASSUMED] and block manufacturing output until resolved.
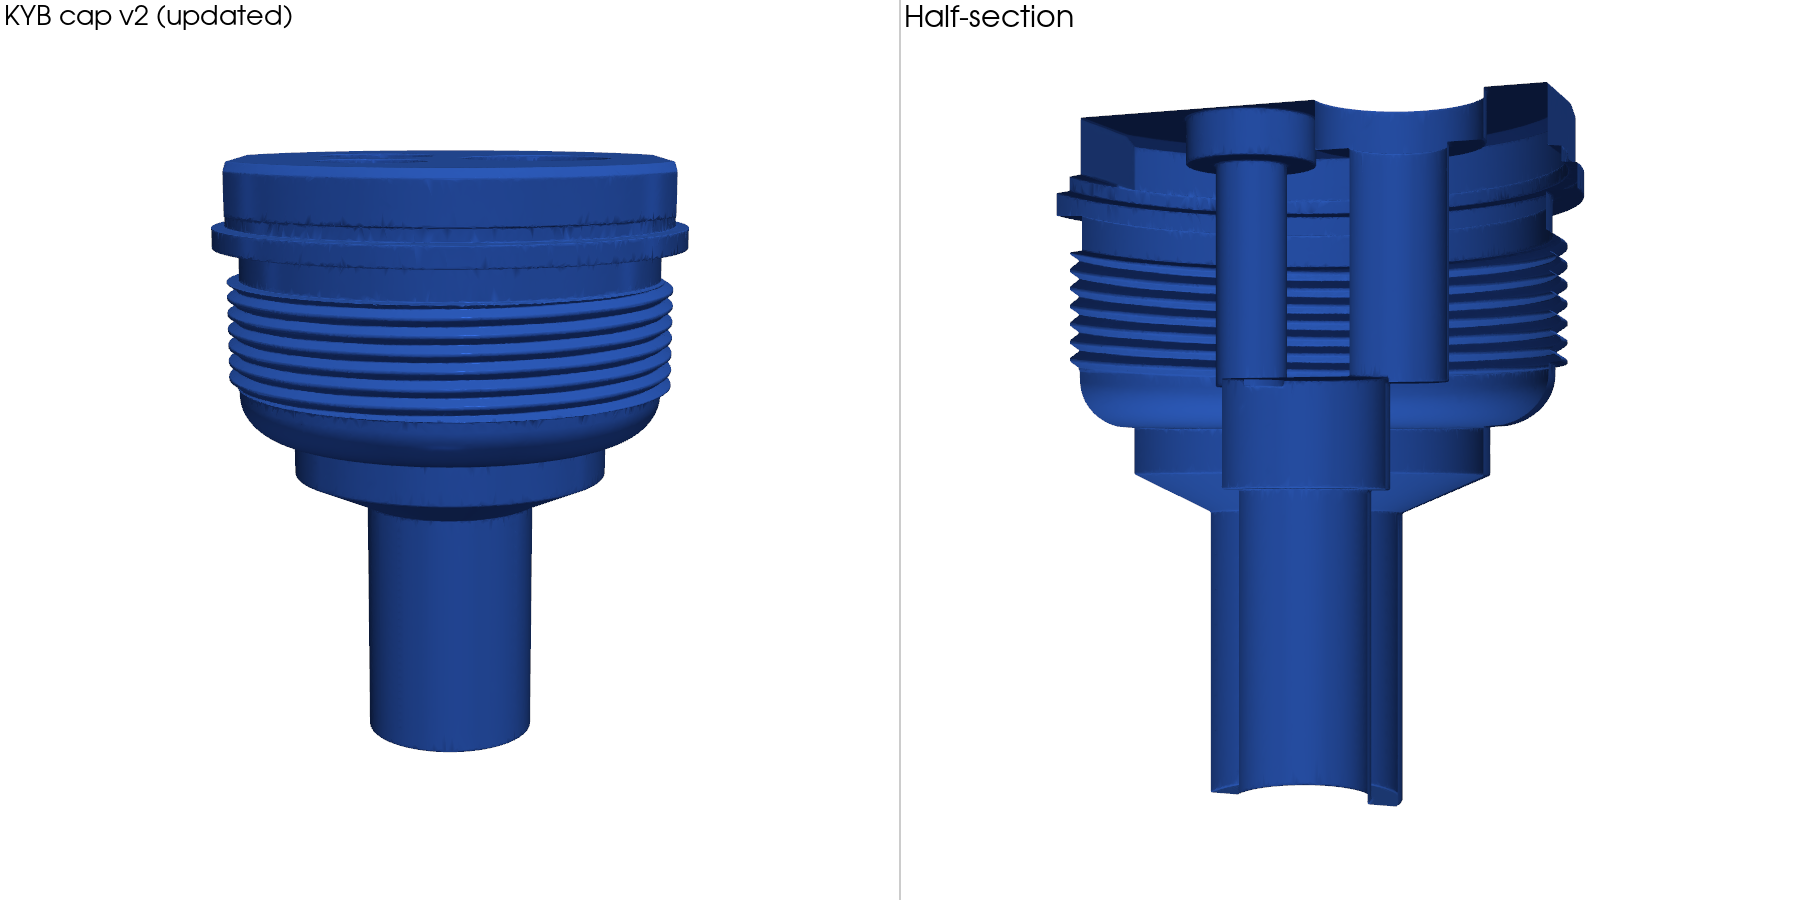
| thread_crest_d | 41.9 mm | locked · caliper |
| thread_pitch | 1.5 mm | locked · caliper |
| overall_length | 55.62 mm | locked · caliper |
| stem_od / stem_id | 16 / 11 mm | locked · caliper |
| groove_depth | ? | assumed · blocks export |
| fillet_r | 0.6–1.2 mm | free · optimizer |
Which dimension moves which mode is the Pilot resonance-mapping program. The sensitivity bars below are a schematic of the method, not a completed sweep.
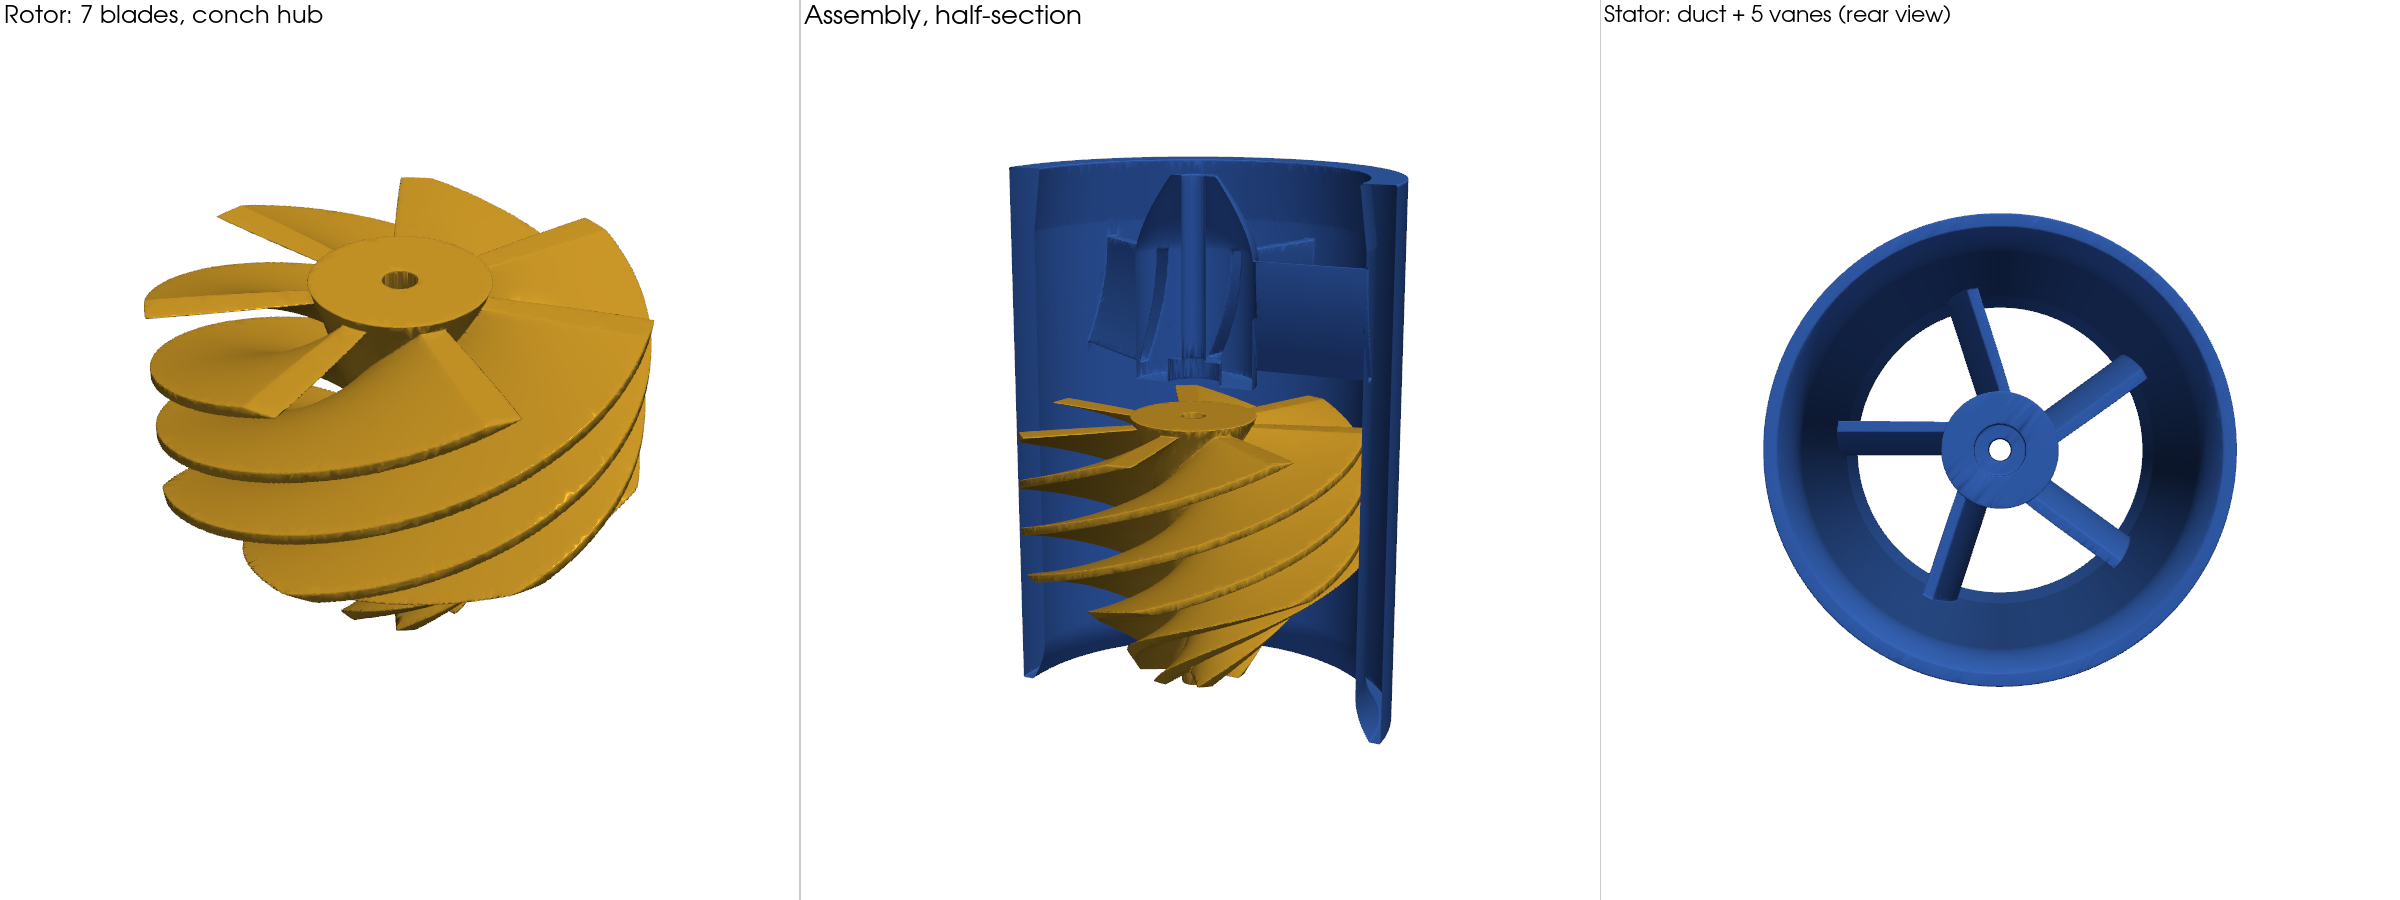
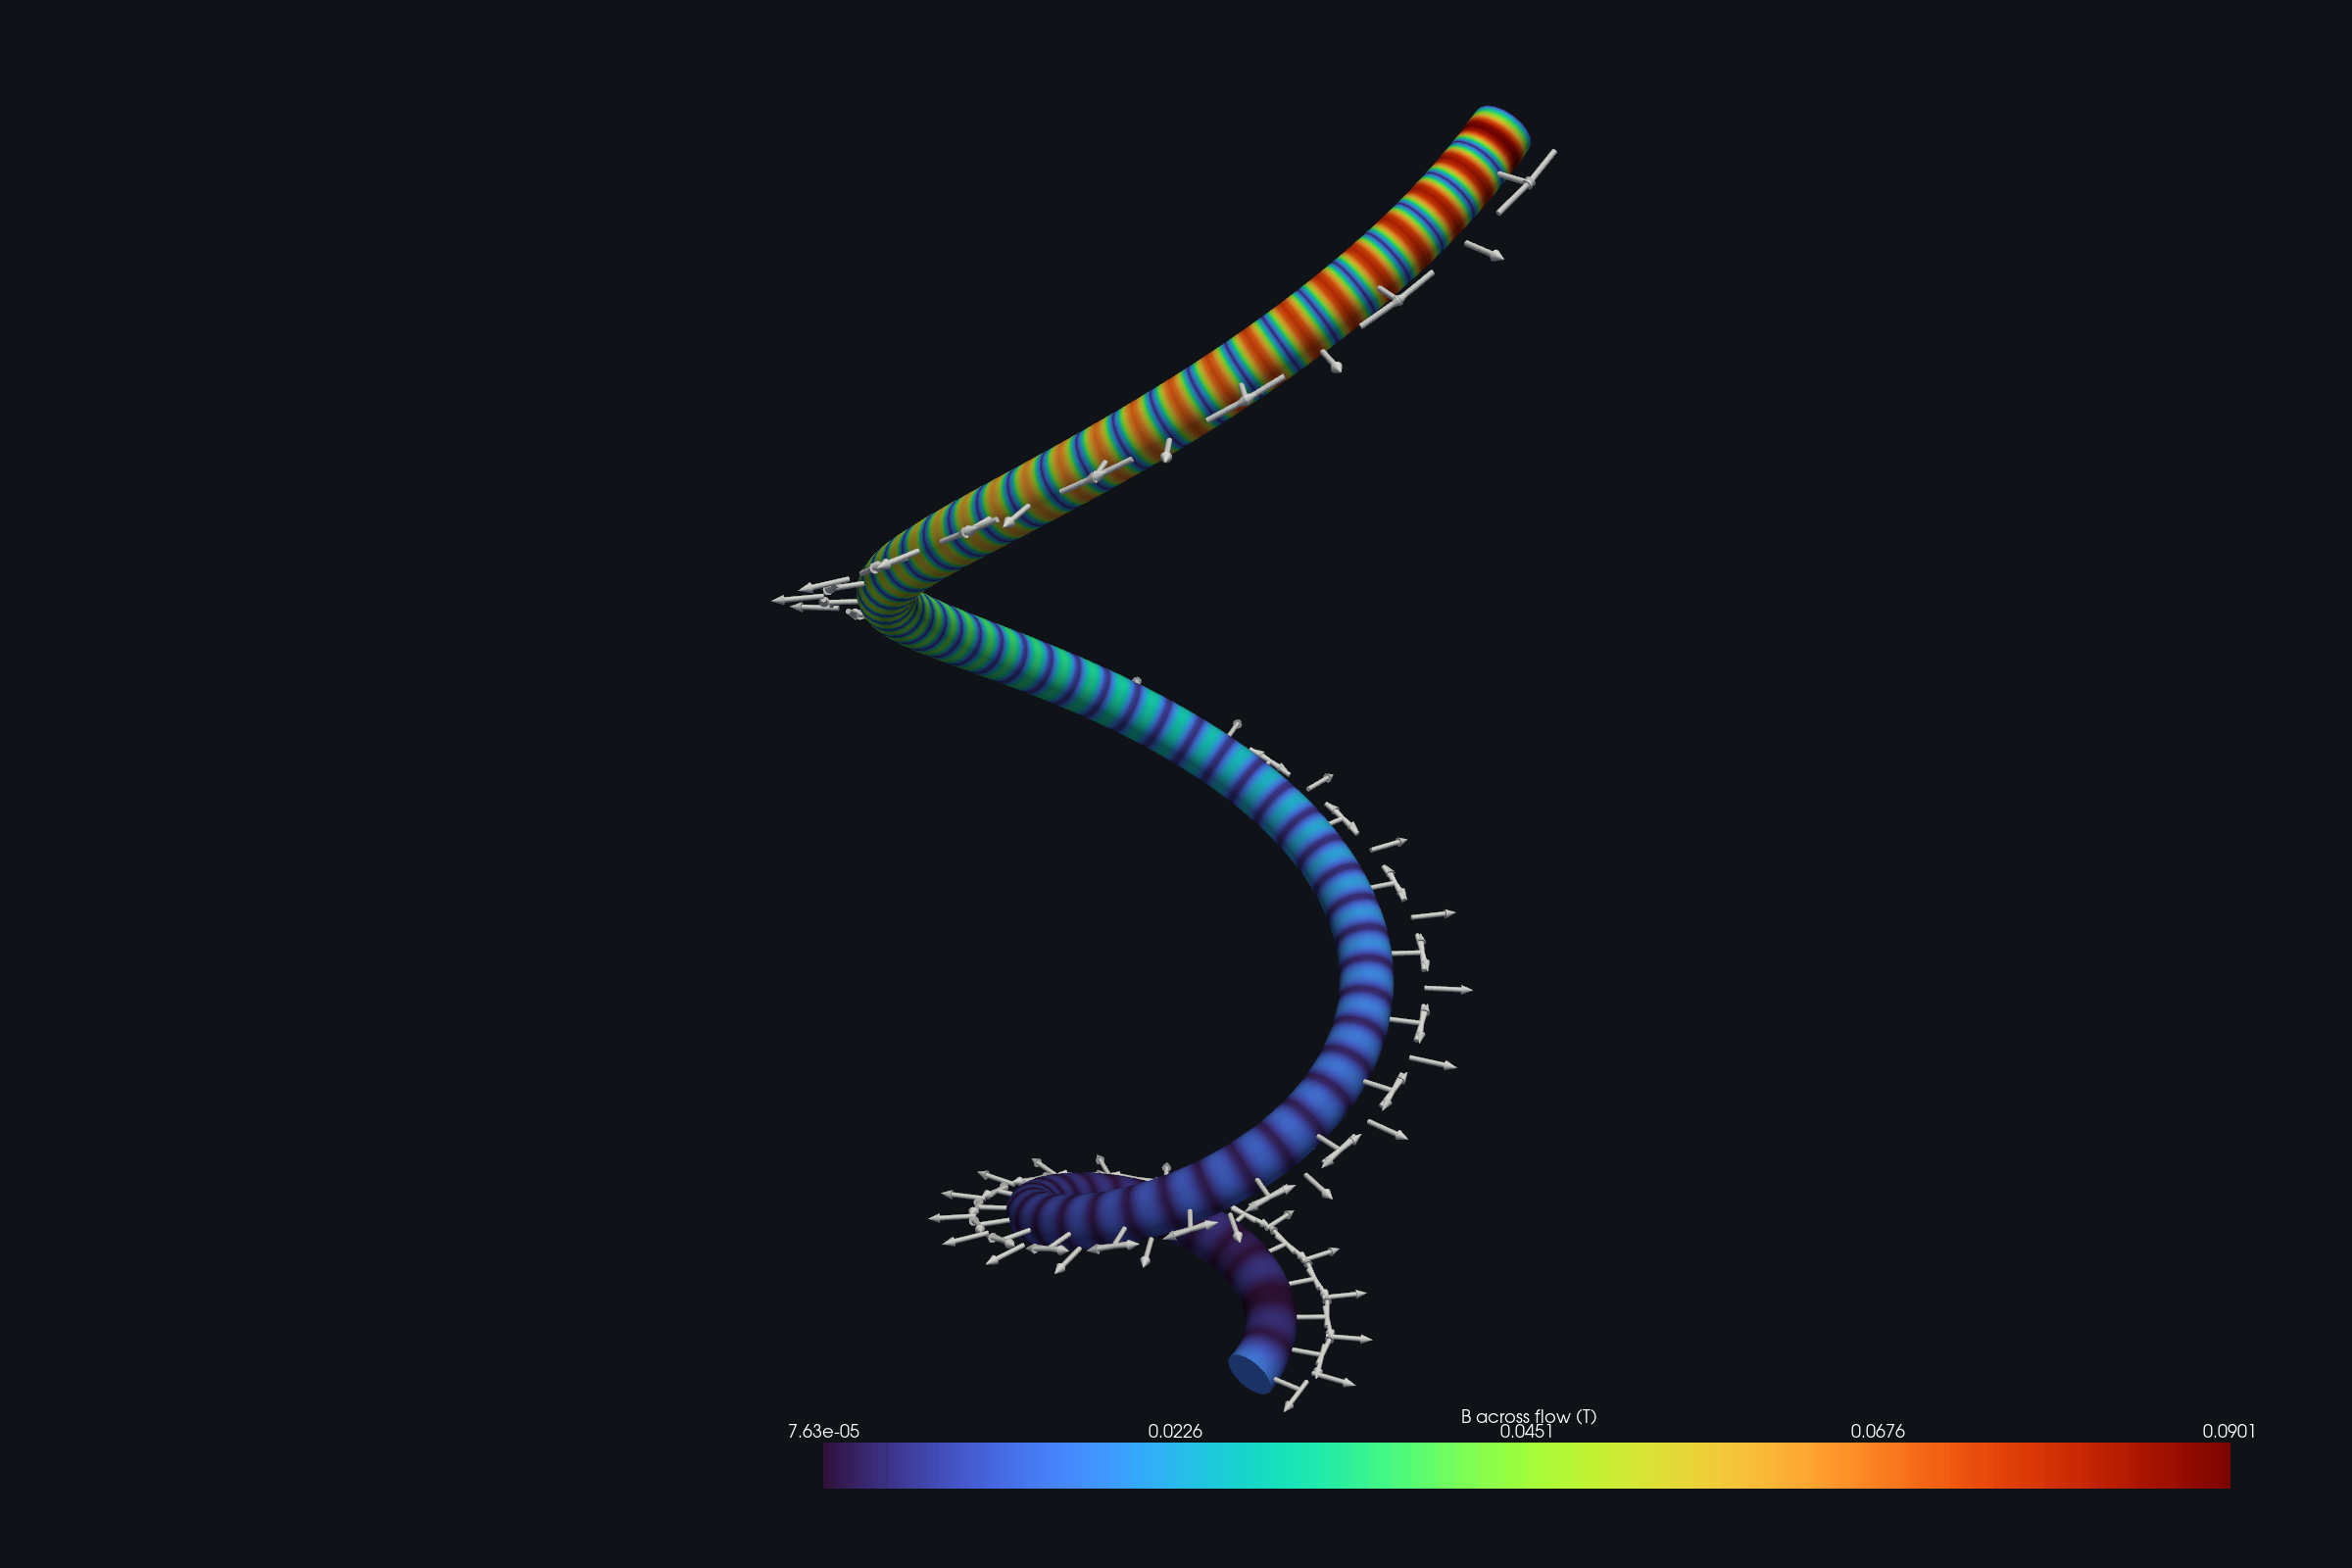
The seven-blade helical thruster has a computed electromagnetic field map today. Its OpenFOAM run is queued, so the streamlines over the duct are a visualization of the question, not a result.
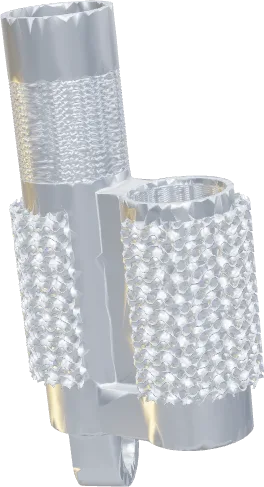
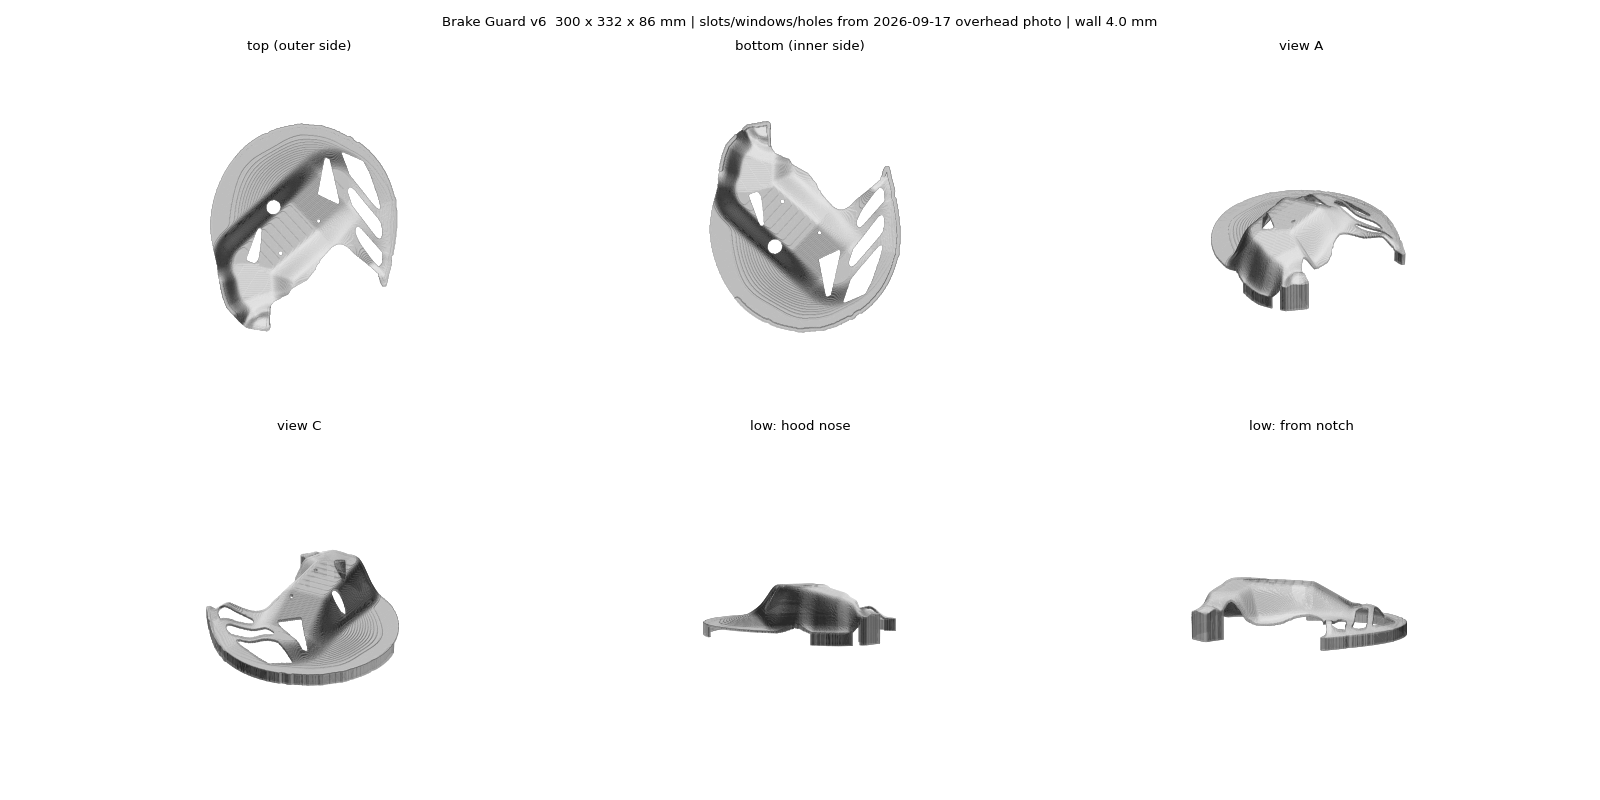
Brake guard: fitted model from photos + calipers; print and fit check pending.
Each program says what exists now. Magnetometry is software research on simulation and public data; no magnetometer hardware is owned. Biomagnetic work is research, not a medical device.
Sweep geometry, material and boundary conditions through modal analysis; rank which dimension moves which mode away from a known excitation band.
A submersible localizes against the seafloor's magnetic anomaly map without GPS or beacons. ScanIQ's role is forward modelling, discrimination and provenance.
Rented GPU pods decode and augment phone photo and video streams so reconstruction never waits on the CPU.
Separate fetal cardiac magnetic signals from maternal and environmental components, then map candidate sources in 3-D. No diagnostic or clinical claims.
The physics changes by industry; the operating principle does not: capture the real object, preserve source provenance, solve the question that matters, and keep the uncertainty visible.
Fork caps, rocker linkages, shock bodies and exhaust sound decision support.
Ducted thrusters, AUV geometry and magnetic-anomaly navigation research.
Reverse-engineered brackets, propulsion concepts and lattice mass removal.
Photo-to-spare workflows and GPS-denied navigation research.
Orthotic/prosthetic geometry plus fetal biomagnetic signal research.
Rebuild obsolete parts from photos, calipers and surviving interfaces.
Wear parts, brackets and machine telemetry interfaces.
Conformal heat-exchanger channels and vibration studies for rotating equipment.
Equipment spares and magnetic-field simulation for survey research.
Bracket and bogie resonance screening and replacement-part reconstruction.
Custom grippers and lightweight arms optimized around the actual workspace.
Battery enclosures, motor mounts and cooling geometry.
As-built capture toward parametric models and digital fabrication.
Non-contact capture to replica or fit-check artifact.
Resonance-tuned bodies and Helmholtz-style acoustic geometry.
Geometry capture and structural screening for custom sports components.
Non-contact artifact capture and reversible digital replication.
A phone-centered physics lab: capture, reconstruct, solve, inspect.
Reverse engineering, failure-analysis support and inspection-ready models.
Repair parts and custom-fit objects made from the object in hand.
Phone camera or LiDAR, webcam, photos, or a 3D file. No account needed.